A
Catalogue mass
The published typical weight for that class. It ignores the box entirely, and is therefore immune to a loose box, which is the common failure.
Technology
Three steps, each checkable on its own. The interesting problems were in the second and third.
01
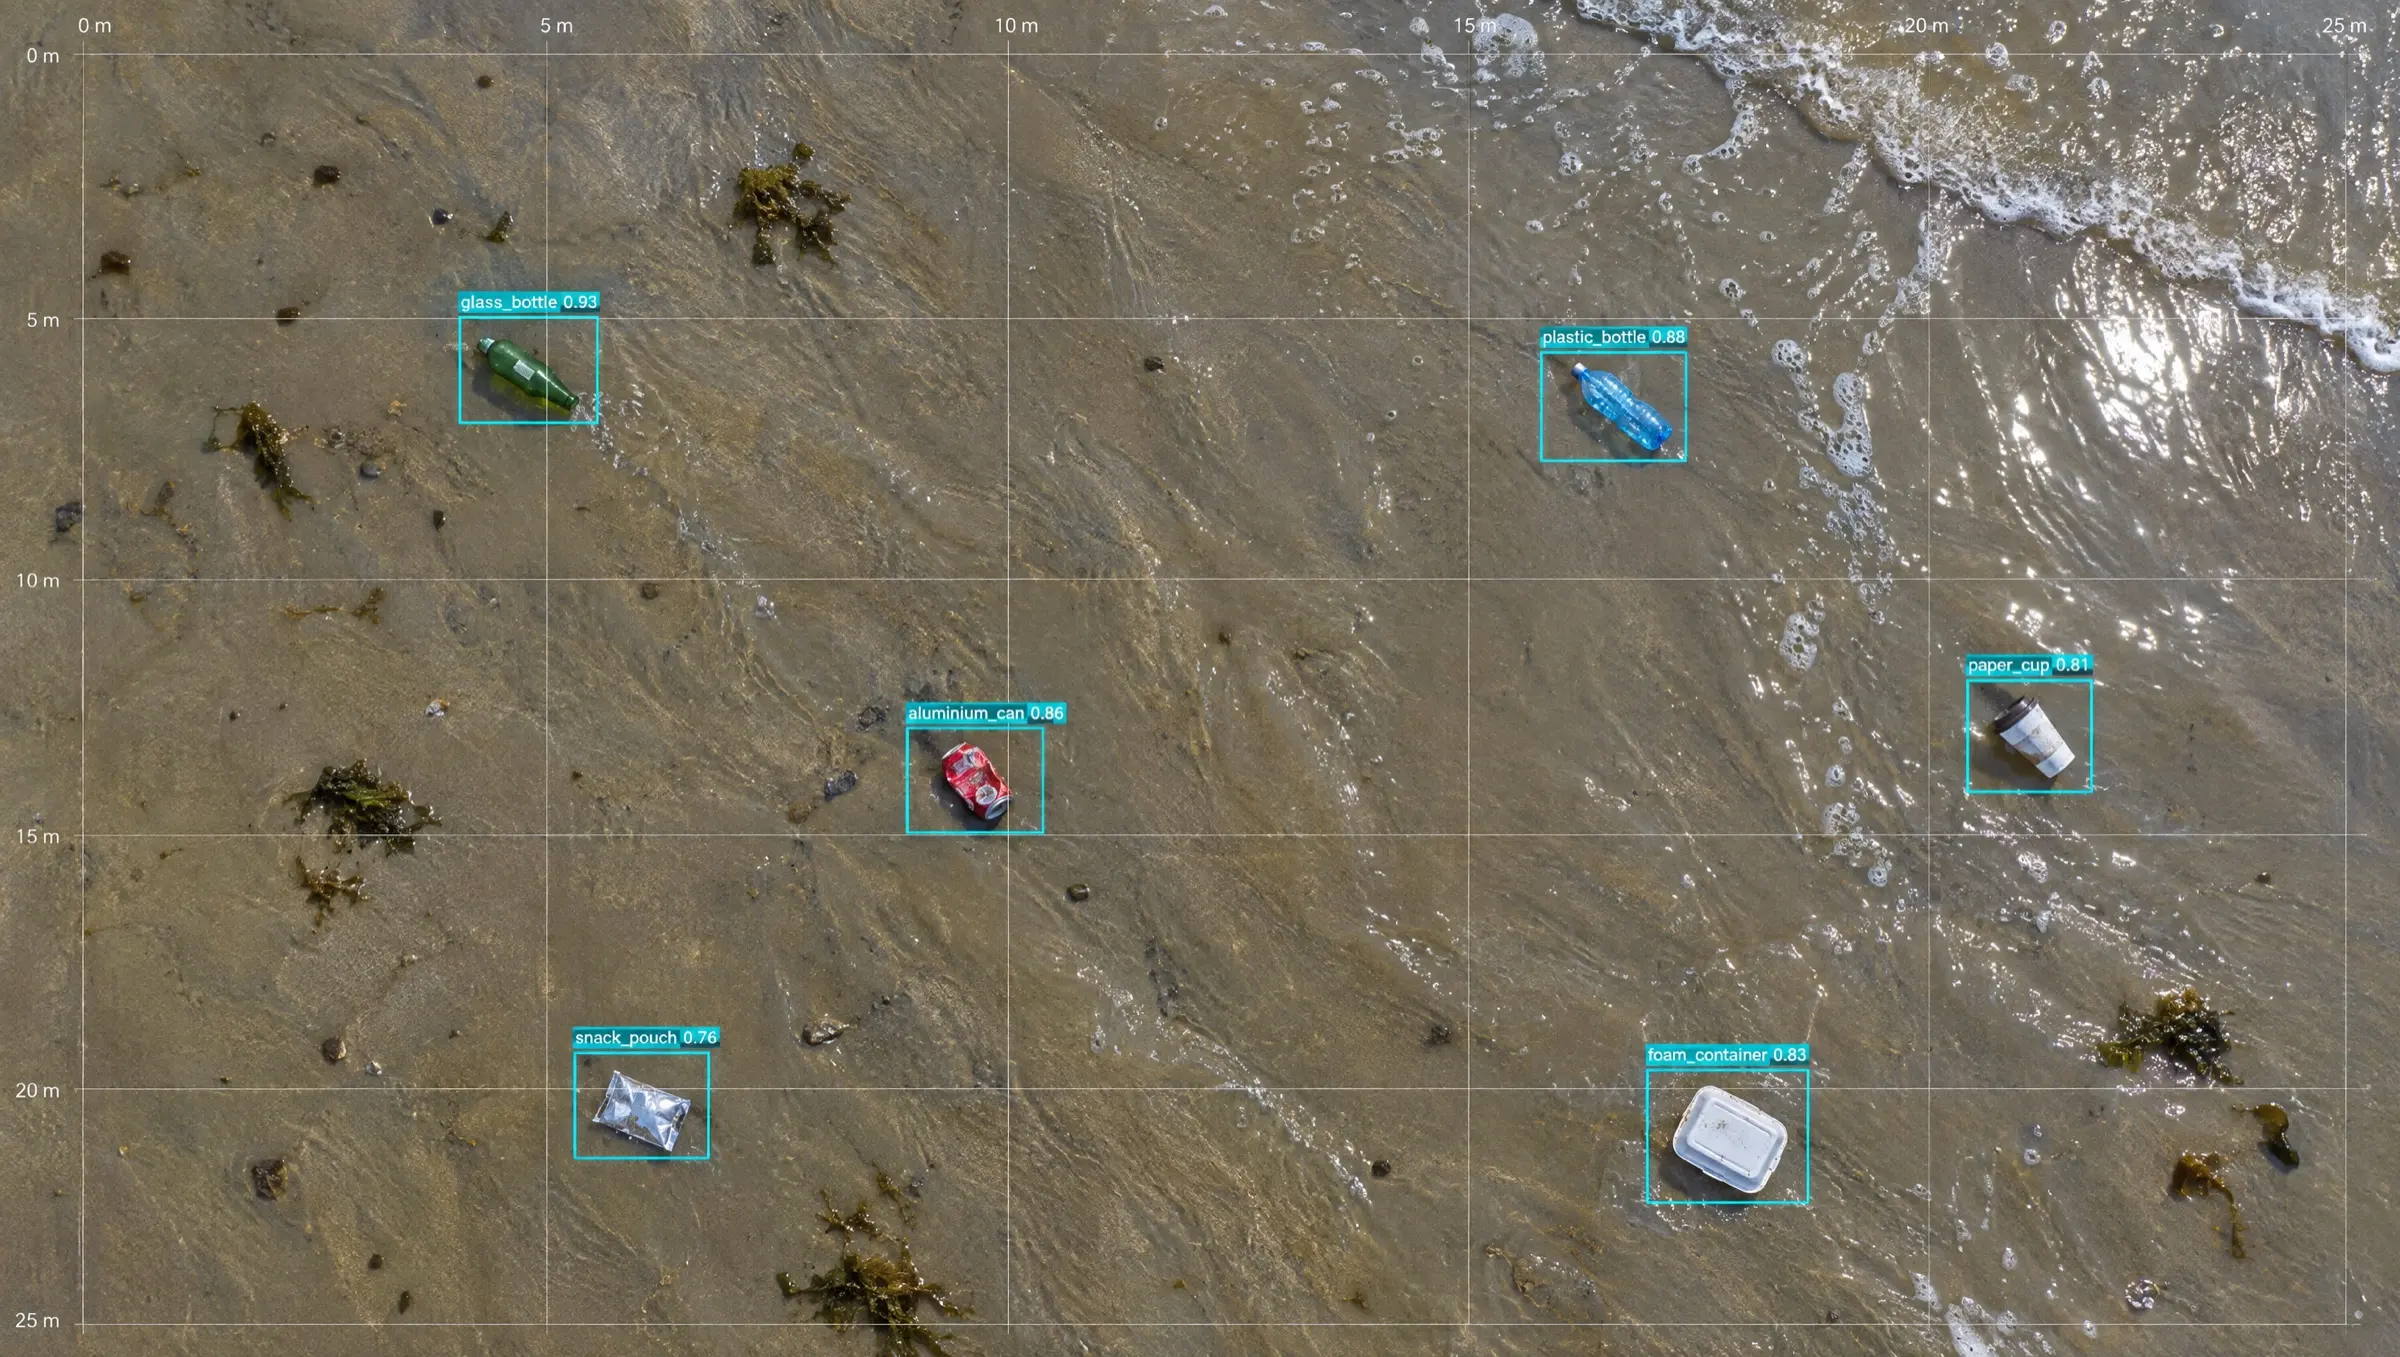
SAAF draws a tight box around each item rather than a pixel mask. Litter in an aerial frame is small, about 60 pixels on its longest side in a 3840×2160 capture, so every frame is read at full resolution rather than downscaled.
Both scores below were measured on imagery the model had never seen. 100% is perfect.
What mAP is
Mean average precision is the standard score for object detectors. It combines how much of the real litter was found with how few false alarms were raised, averaged over all six classes. The number after the @ is how tightly a box must fit the item before it counts: at 50 it must cover half the item, at 50-95 it is scored again and again up to a near-perfect fit and the results averaged. A loose box passes the first test and fails the second.
02
A detection box is an axis-aligned rectangle. Turn a 22×7 cm bottle by 45° and the smallest upright box that contains it is a 20.5×20.5 cm square,2.7× the object's real area. A detector that is casual about orientation draws loose, square boxes, and every area and mass downstream inherits the error.
So box tightness is scored on its own, as mAP@50-95, and treated as the number that matters. Getting it right was the single largest improvement in the project, and it came from how the boxes are drawn rather than from a bigger model.
03
Pixels become centimetres through the ground sample distance. Everything downstream is a multiple of this one number, so it is the only value that has to be right for the areas to be right. It needs the camera model and the flight altitude, both of which the pilot already knows.
GSD = sensor_width × altitude ÷ (focal_length × image_width)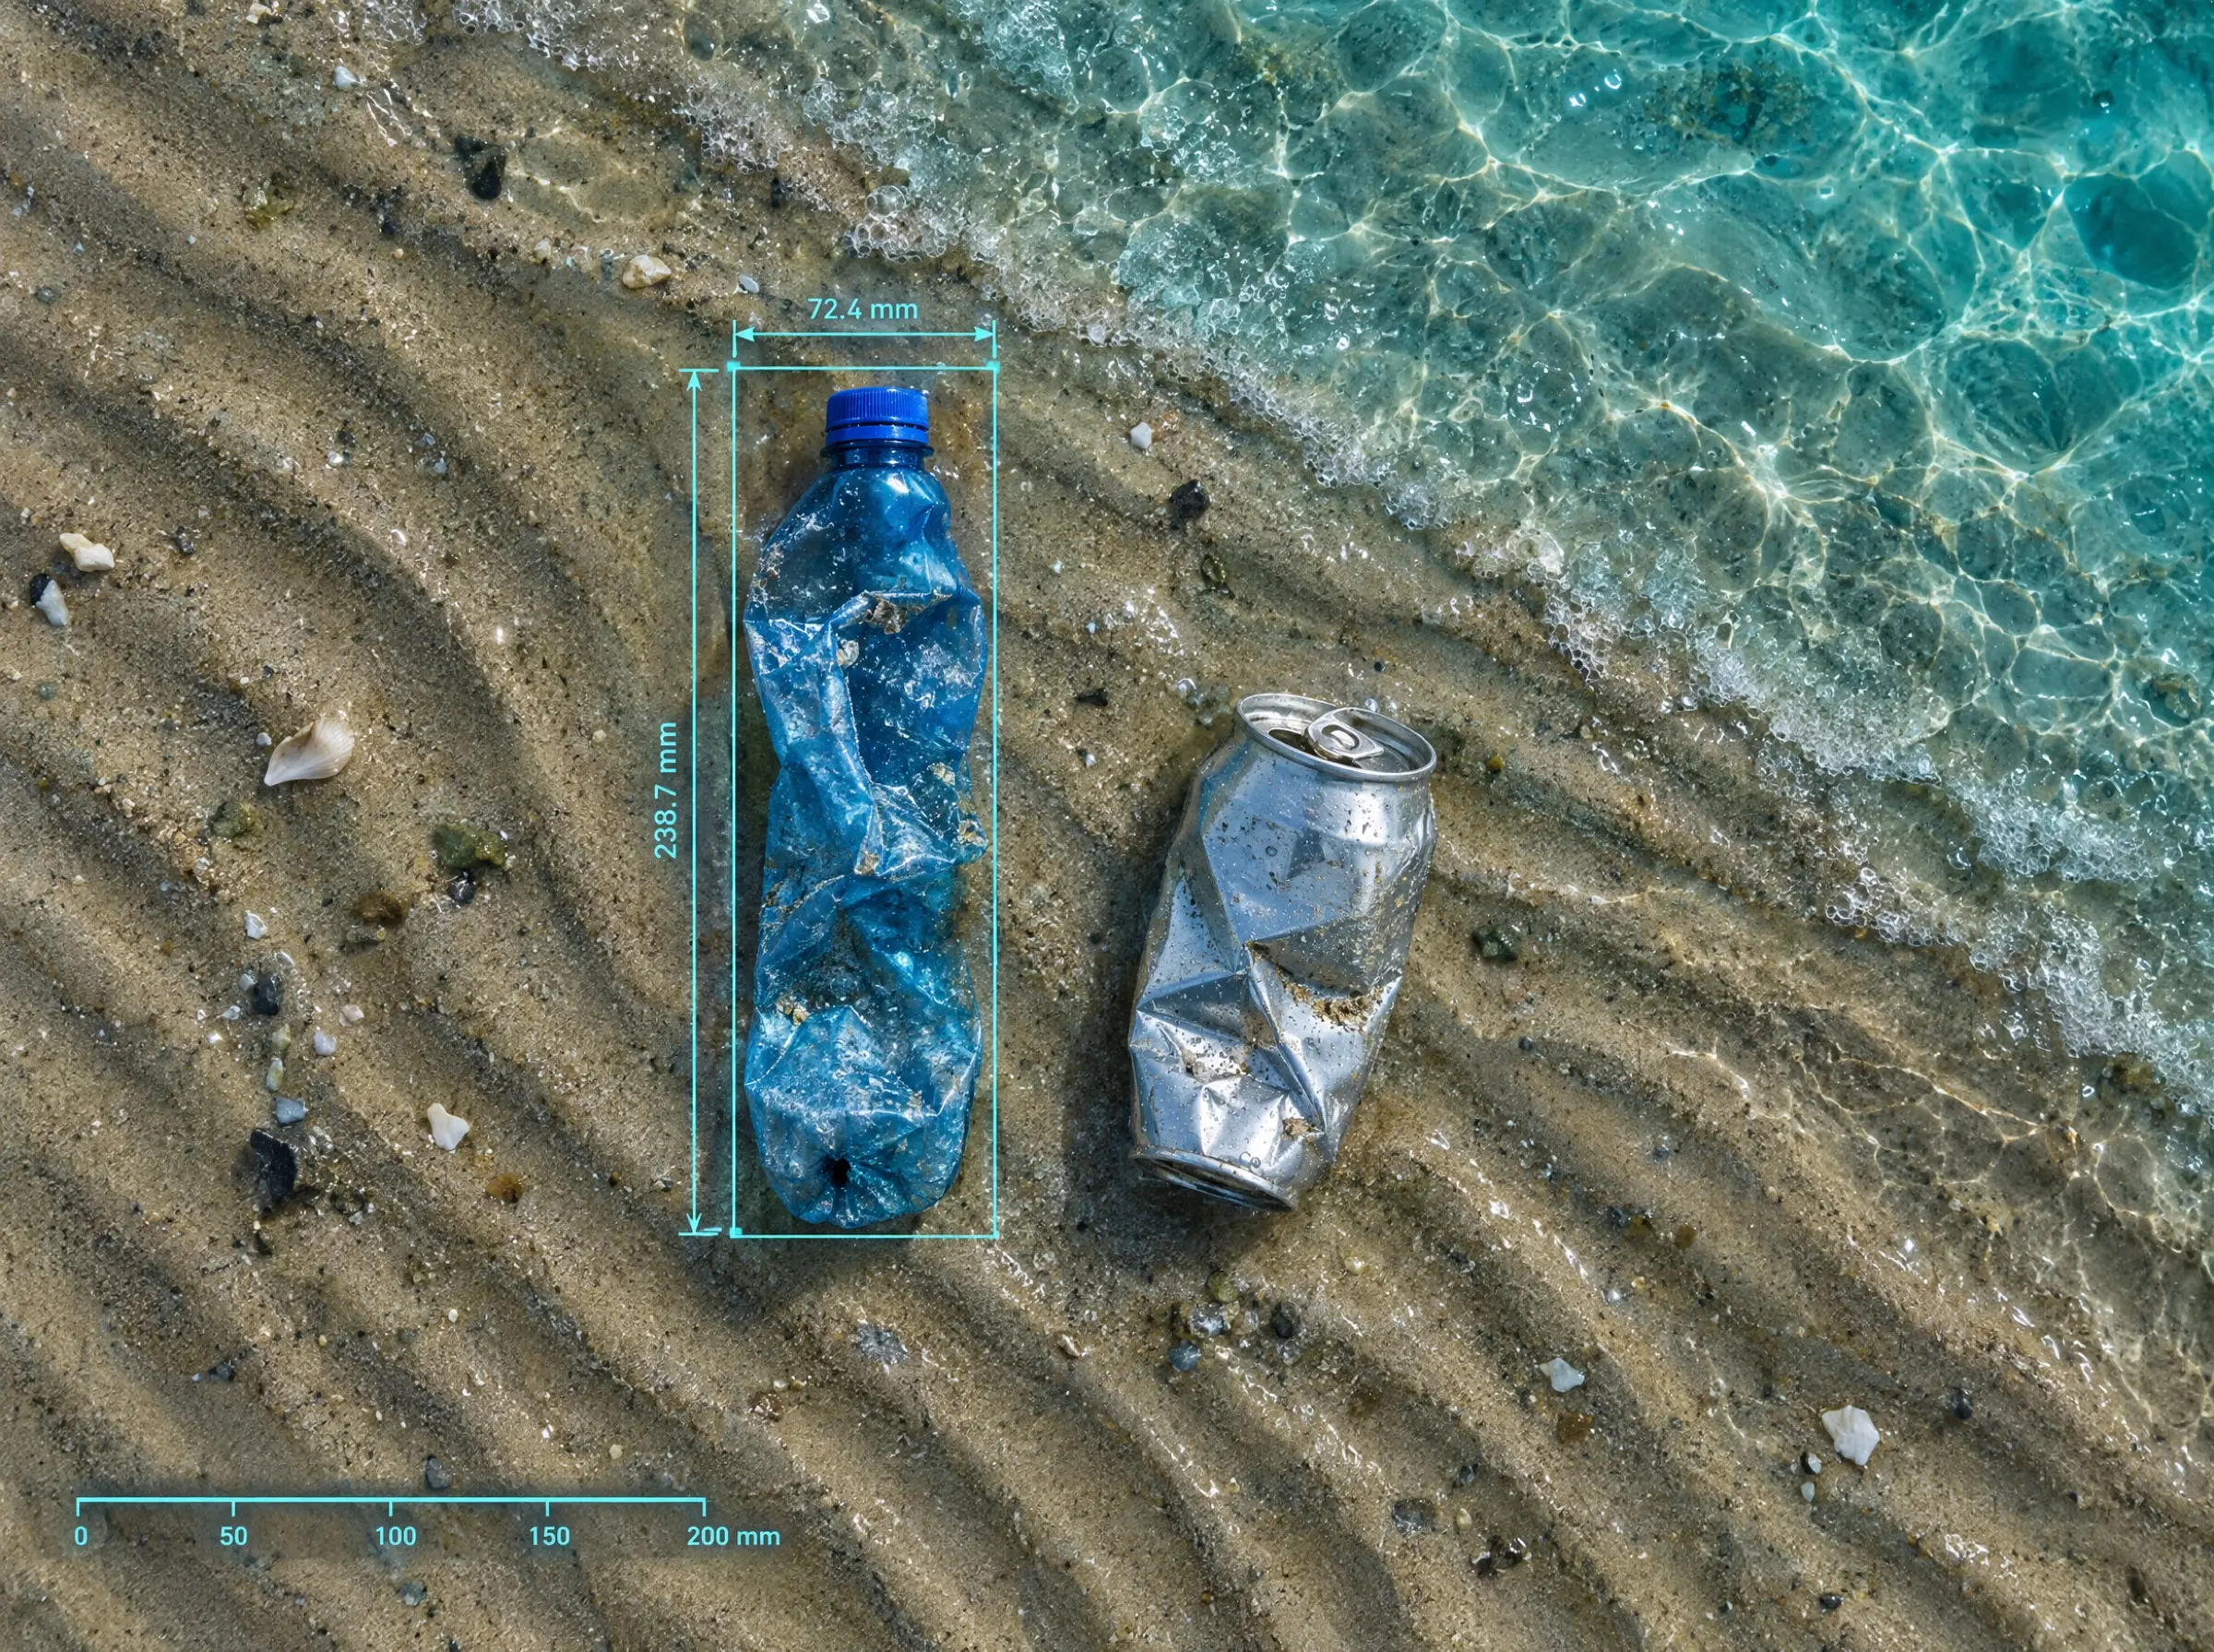
04
A
The published typical weight for that class. It ignores the box entirely, and is therefore immune to a loose box, which is the common failure.
B
Scales that weight by the item's longest side against a reference length. Length rather than area, because a loose box inflates area quadratically: a 2× area error would become a roughly 3× mass error under volumetric scaling. The ratio is clamped hard for the same reason.
When estimates were checked against measured values, guesses missed by 43 to 59%. A glass bottle estimated at 350 g weighs about 220 g. Every weight in the table now has a published source.
05
Stated here so nobody has to discover them in a report.
It comes from reference weights, not a weighing, and it is reported as one everywhere it appears.
Every area and mass scales linearly with the recorded altitude. A wrong altitude is a wrong survey.
Partially buried or submerged items are under-measured. What the camera cannot see is not counted.
Waste moves with the tide and the season. A single survey is a snapshot; hotspots and trends need flights repeated across both.
Anything outside them is not counted rather than misfiled. New classes can be added.